 01
AEROSPACEBUILT & FLIGHT-TESTED
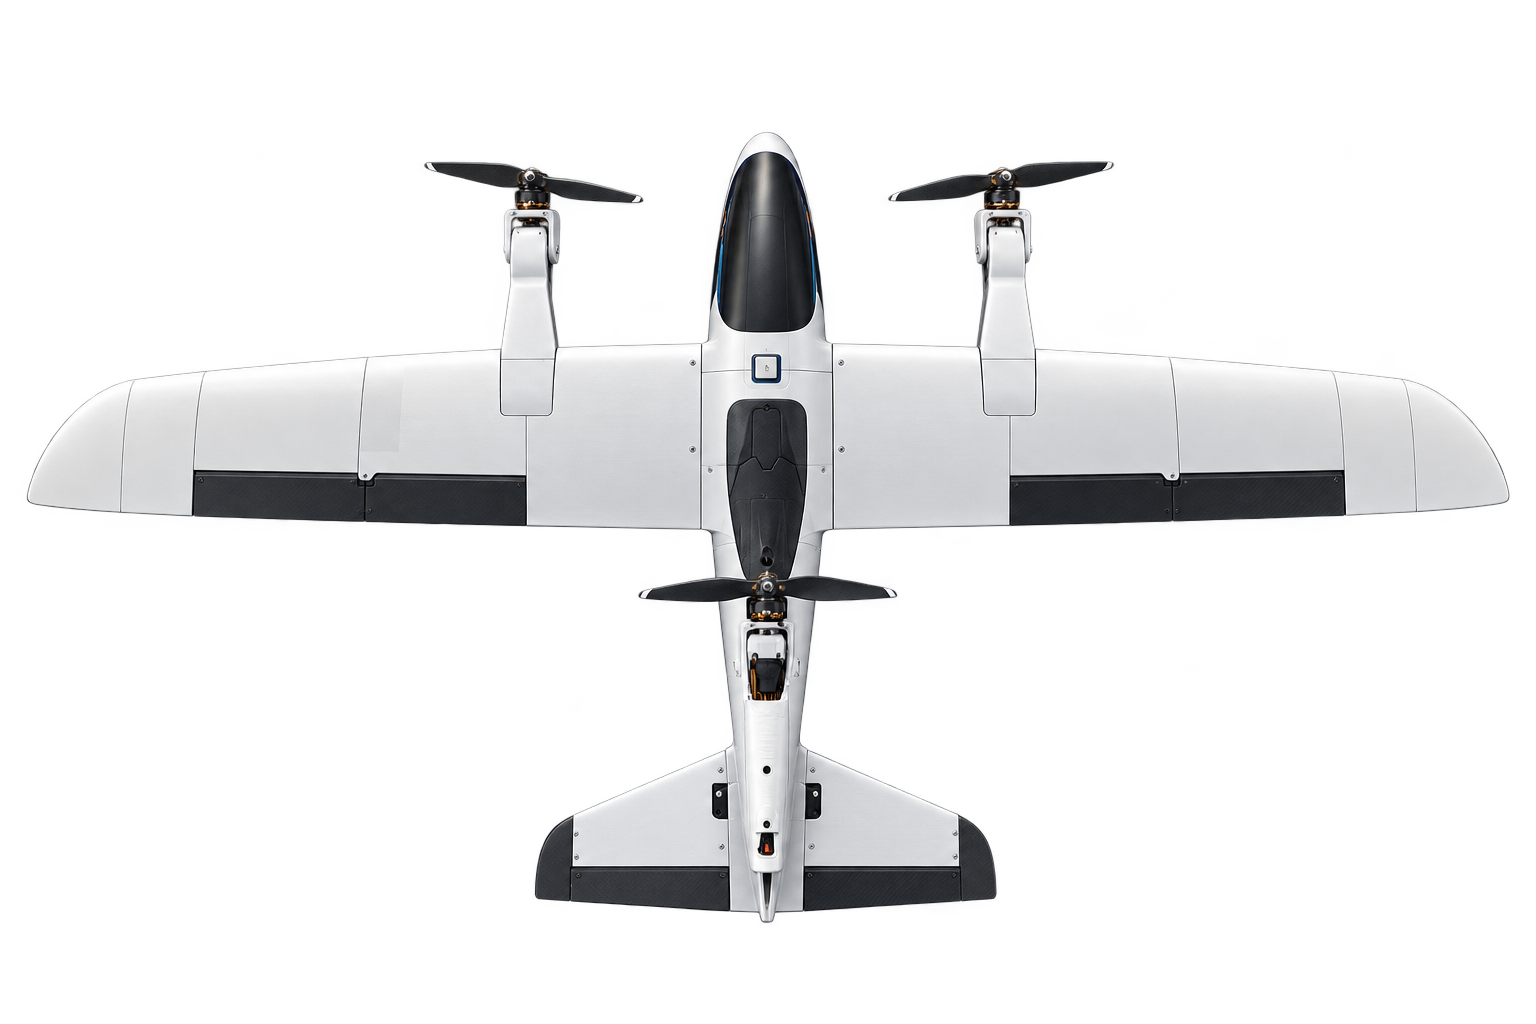
Vector V1 - Tri-rotor VTOL UAV
A fabricated and flight-tested electric UAV using three tilting propulsion units for vertical lift and transition to wing-borne forward flight.
AEROSPACE / REUSABLE ROCKETRY
Reusable model rocket research, with participation in the thrust-controlling team toward autonomous vertical recovery.
Project Raptor investigates a reusable model rocket with autonomous vertical landing as its recovery objective. The work brings flight dynamics, avionics and landing control together around the challenge of repeatable recovery.
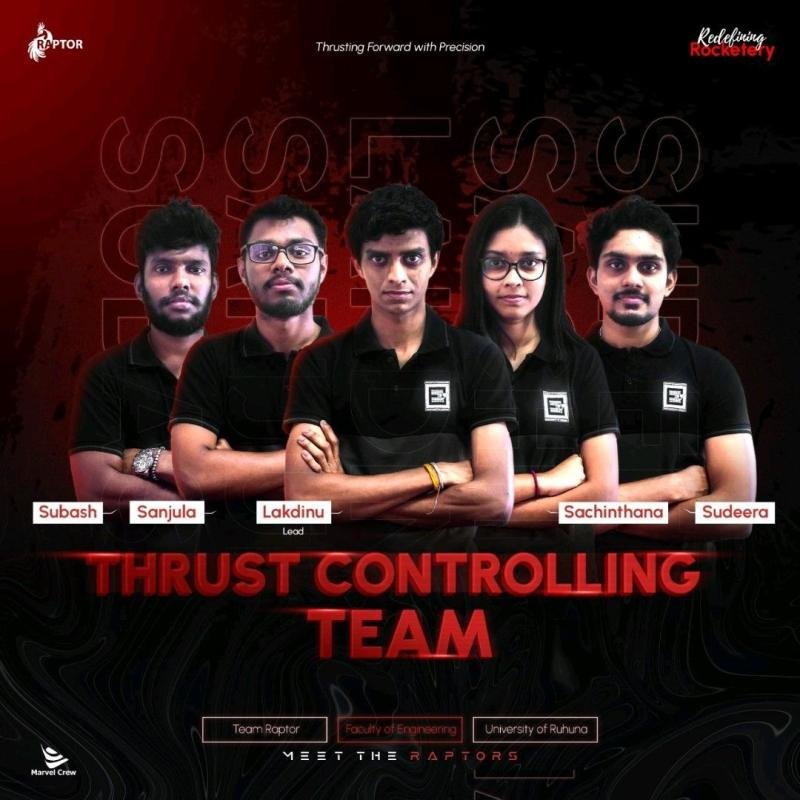
I participated in the thrust-controlling team. The supplied team artwork identifies Subash, Sanjula, Lakdinu, Sachinthana and Sudeera, with Lakdinu marked as the lead.
Thrust control forms part of the wider flight and recovery problem: the rocket must manage its propulsion and motion as it approaches the landing phase. The available resources identify my team membership, while leaving individual hardware and algorithm ownership unspecified.
The project description covers flight dynamics, thrust vector control, onboard sensing and real-time landing algorithms. Its proposed avionics approach includes gyroscopes, accelerometers, barometric sensing and GPS, with prototyping, simulation and testing directed toward controlled recovery.
The supplied photographs document a Project Raptor briefing, the presentation room and the wider project team. They provide a record of the collaborative university research setting alongside the dedicated thrust-controlling team artwork.
The Department of Mechanical and Manufacturing Engineering at the University of Ruhuna announced Project Raptor on 28 January 2023, before the May–November participation period listed in my portfolio.
Autonomous vertical landing remains the stated research objective. The supplied meeting photographs and team records do not document a completed landing demonstration or measured flight performance.
An overview of the documented project scope.
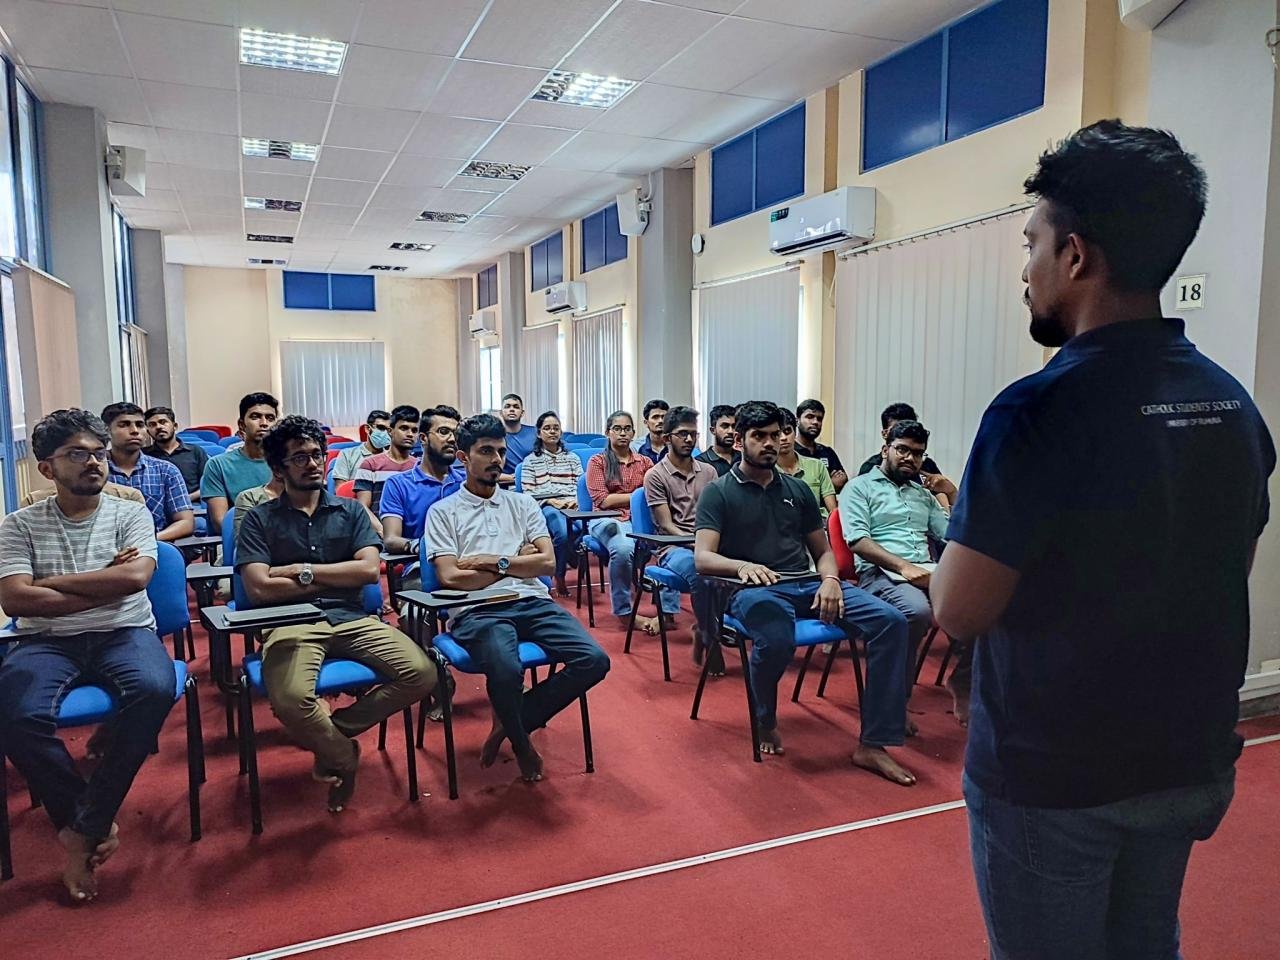
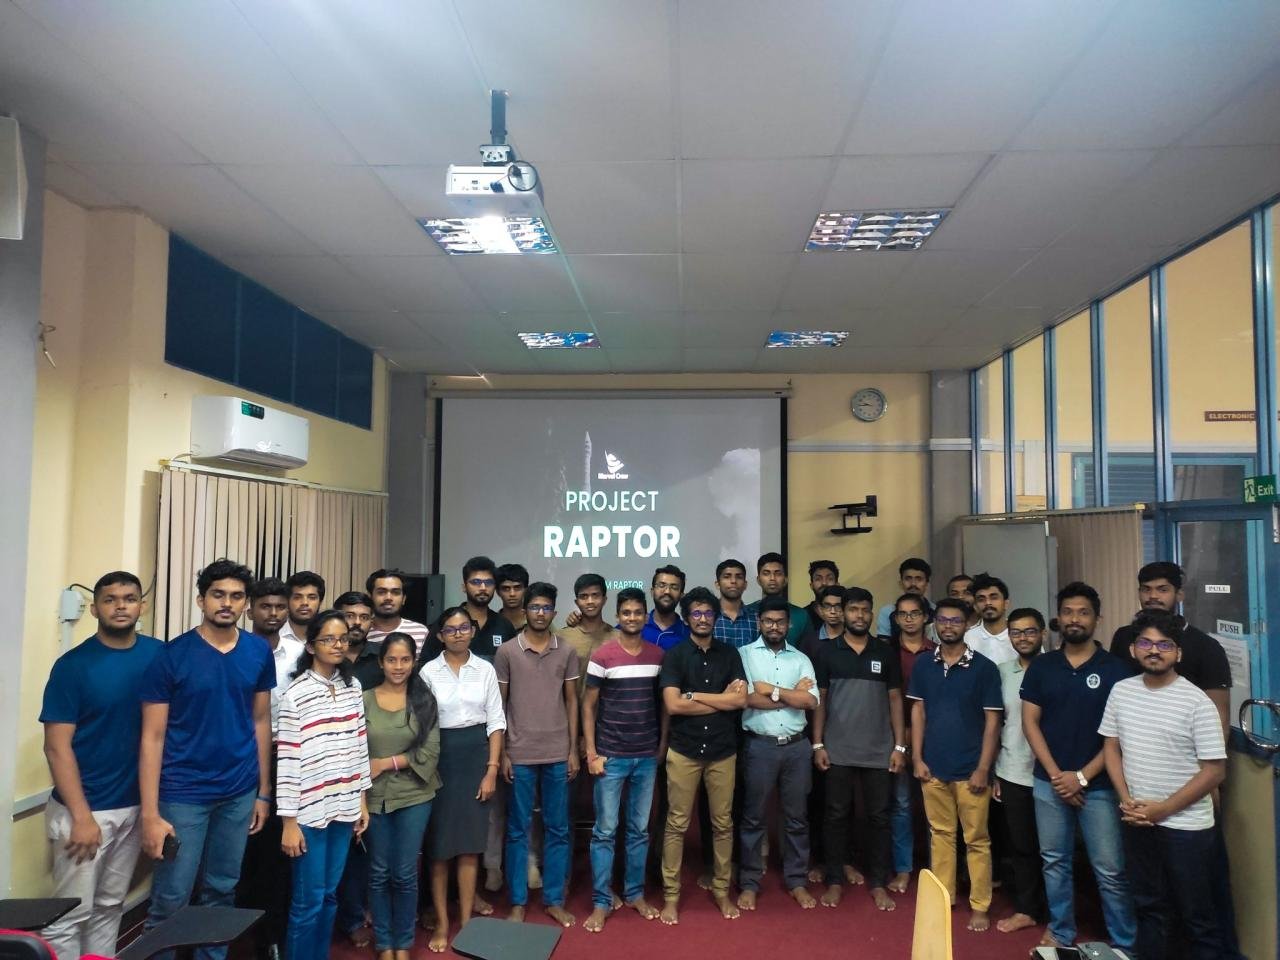
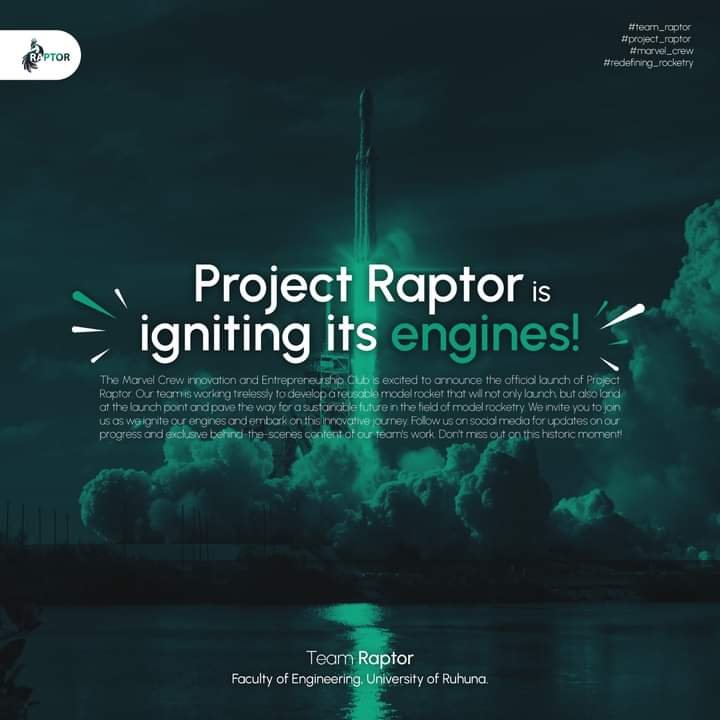
The gallery includes the supplied team artwork and project meeting photographs. The university announcement and public project description provide additional research context.
KEEP EXPLORING
01A fabricated and flight-tested electric UAV using three tilting propulsion units for vertical lift and transition to wing-borne forward flight.
 02
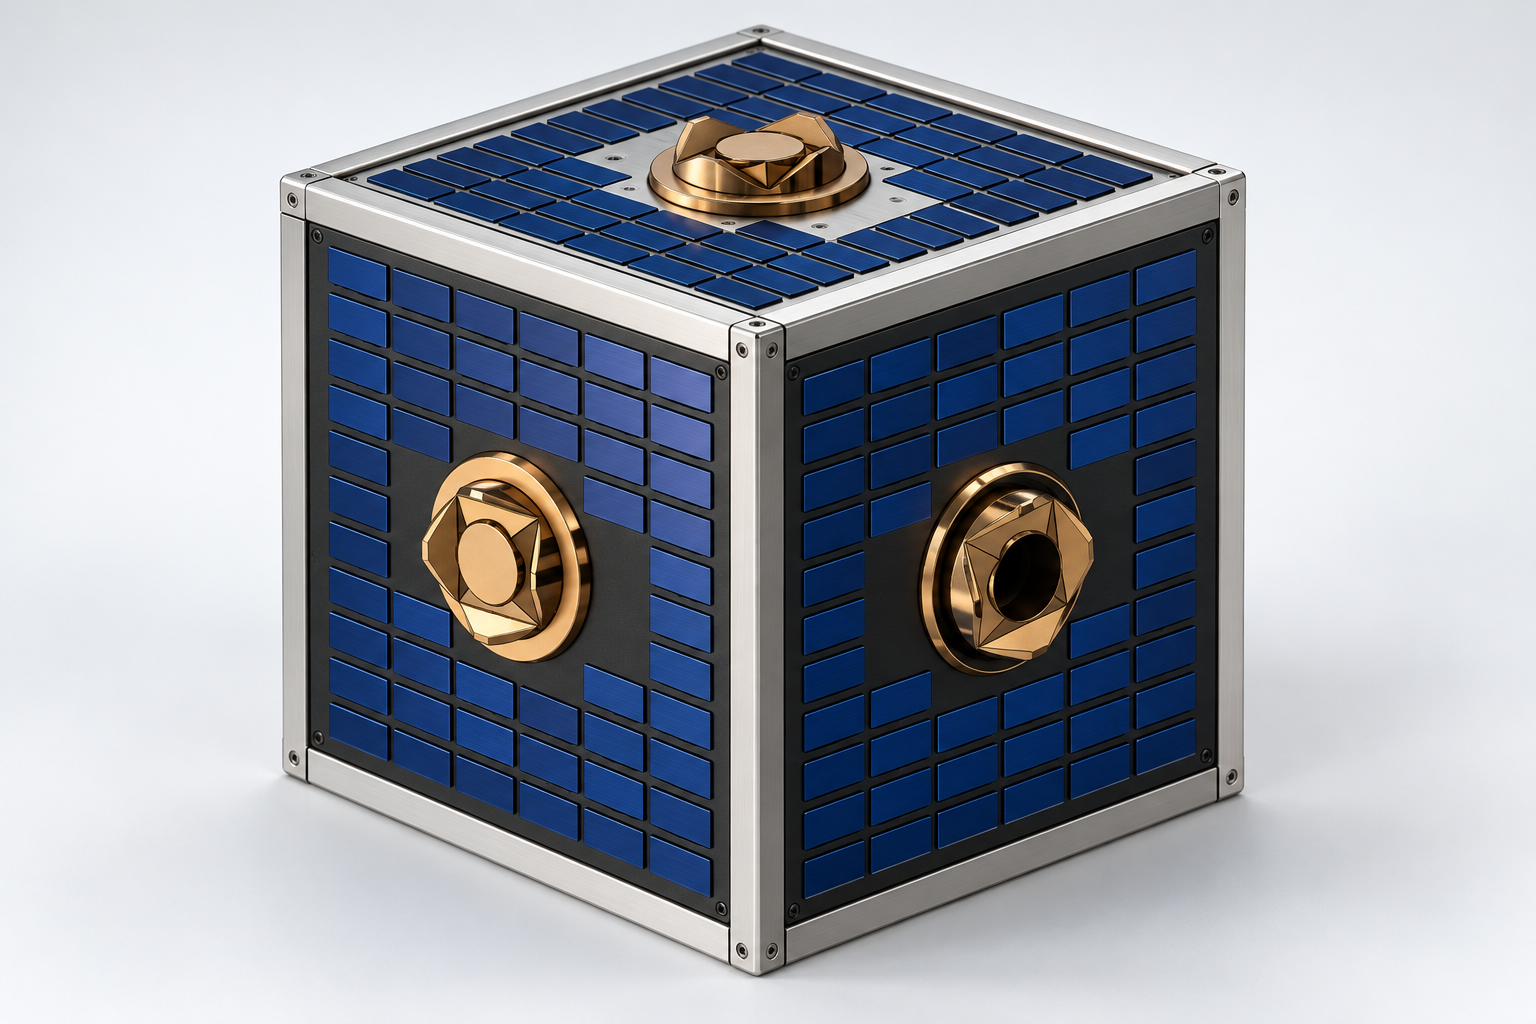
A station-supported free-flying robot design for orbital inspection, positioning, assembly, and servicing, with nitrogen propulsion and six modular docking interfaces.
 03
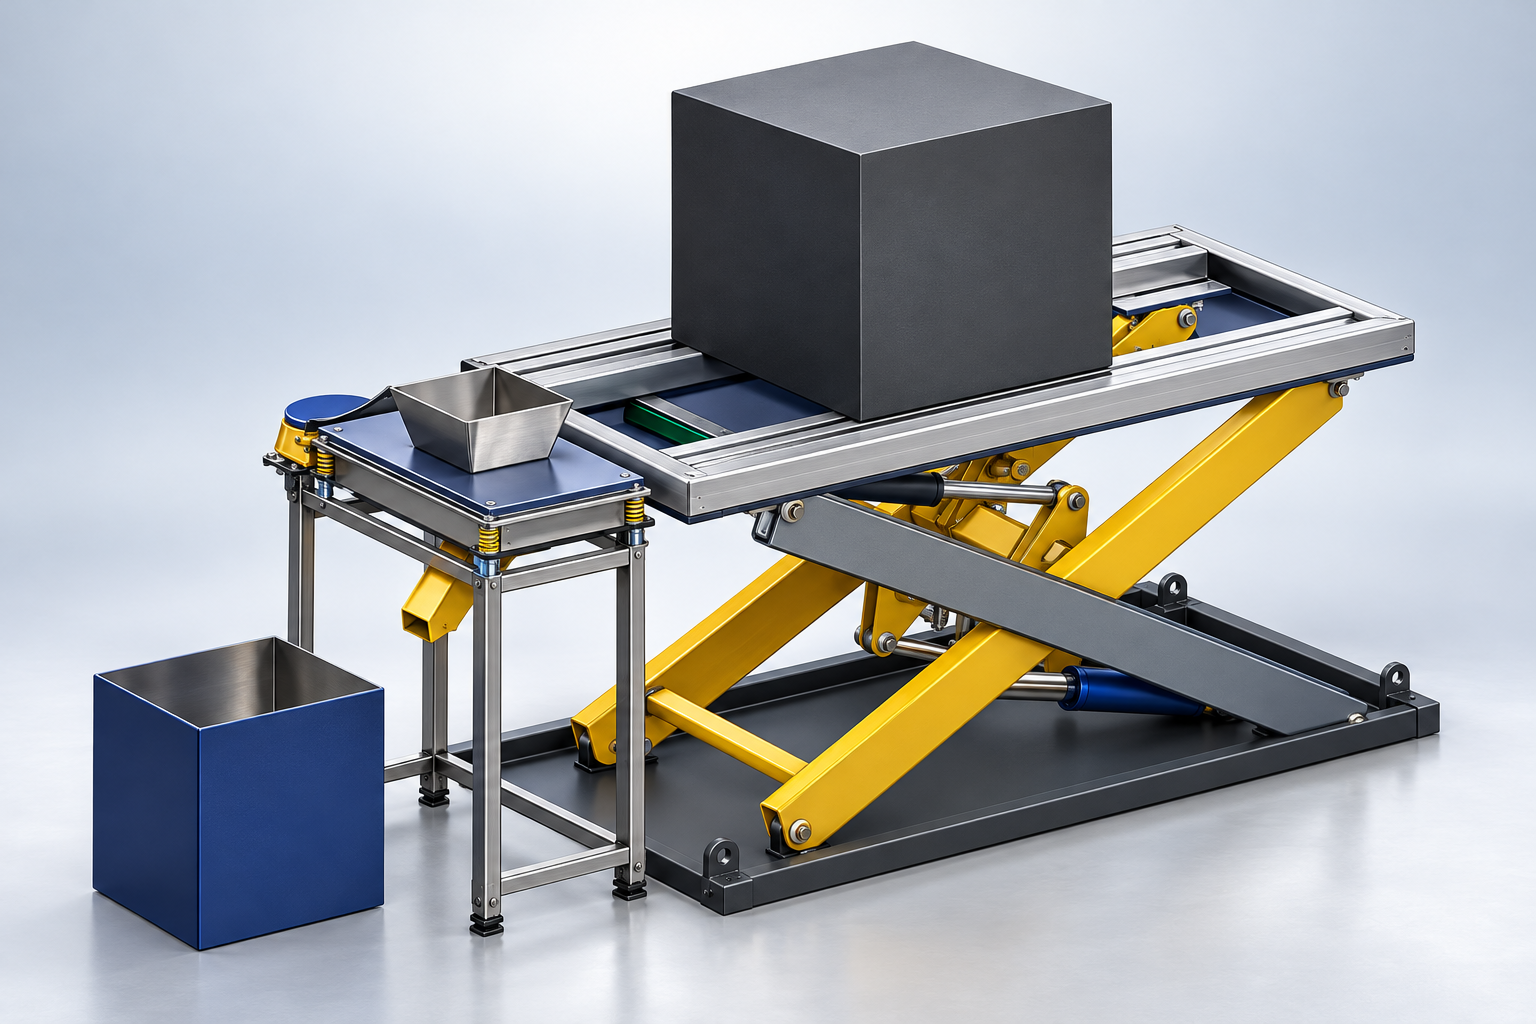
Designed in SolidWorks for Michelin and developed into a siever prototype, combining mechanical fabrication, electrical motor wiring, and hands-on troubleshooting.