 01
AEROSPACEBUILT & FLIGHT-TESTED
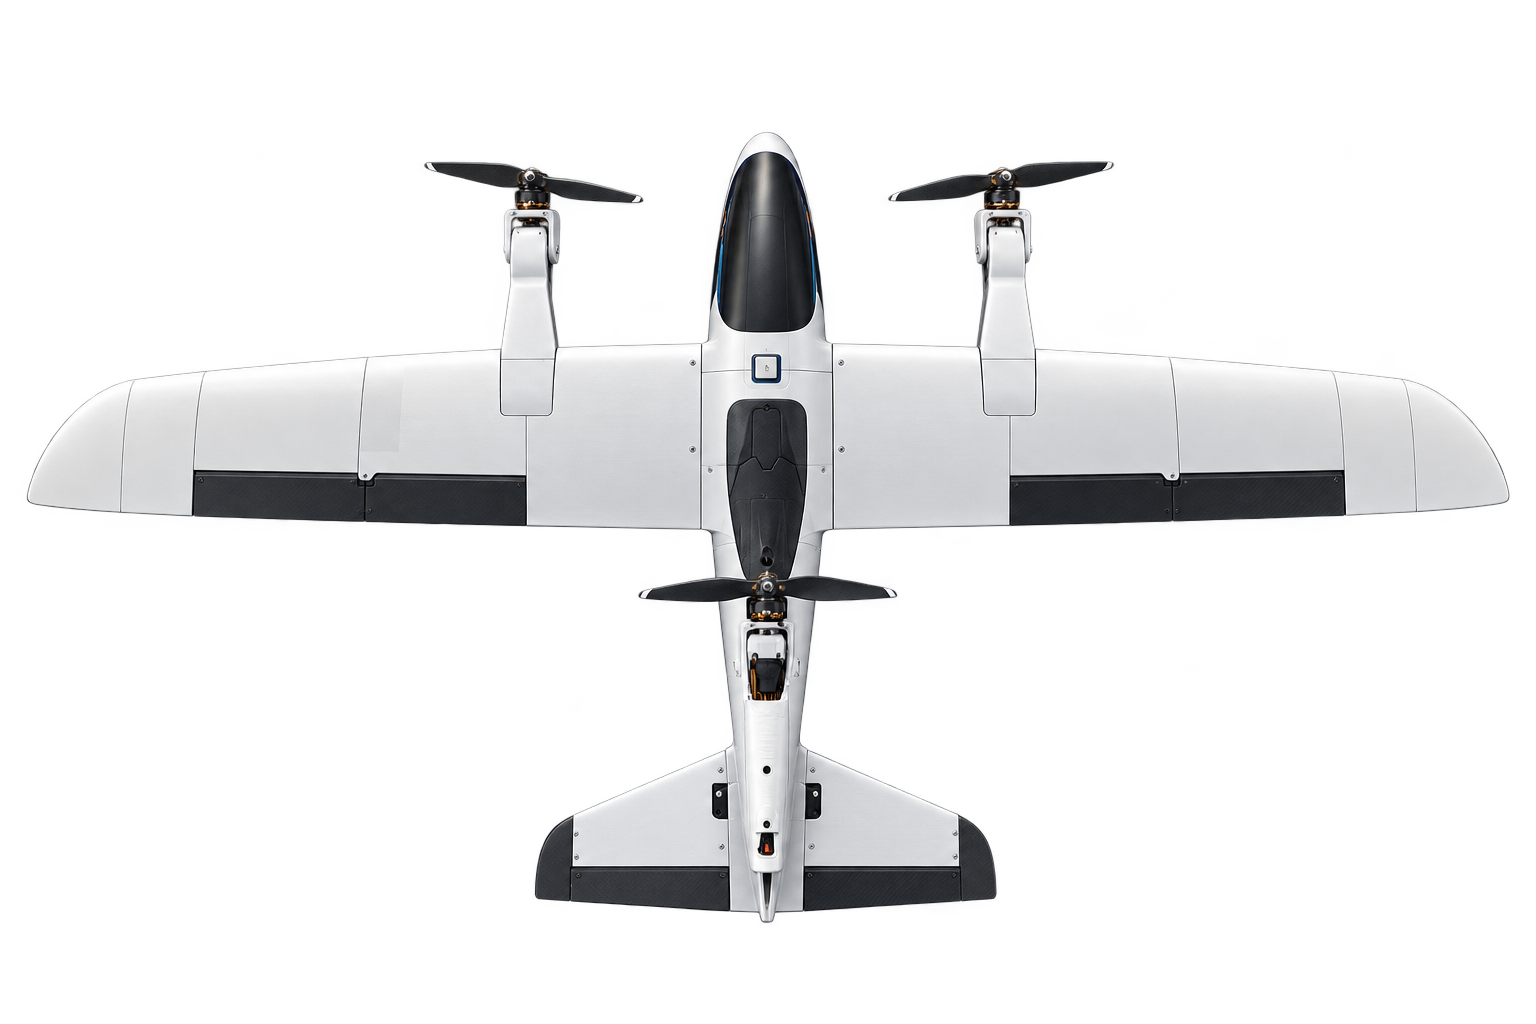
Vector V1 - Tri-rotor VTOL UAV
A fabricated and flight-tested electric UAV using three tilting propulsion units for vertical lift and transition to wing-borne forward flight.
ROBOTICS / XBOTIX 2023
Team Sparkbots’ built robot platforms for the XBOTIX 2023 undergraduate challenge at the University of Ruhuna.
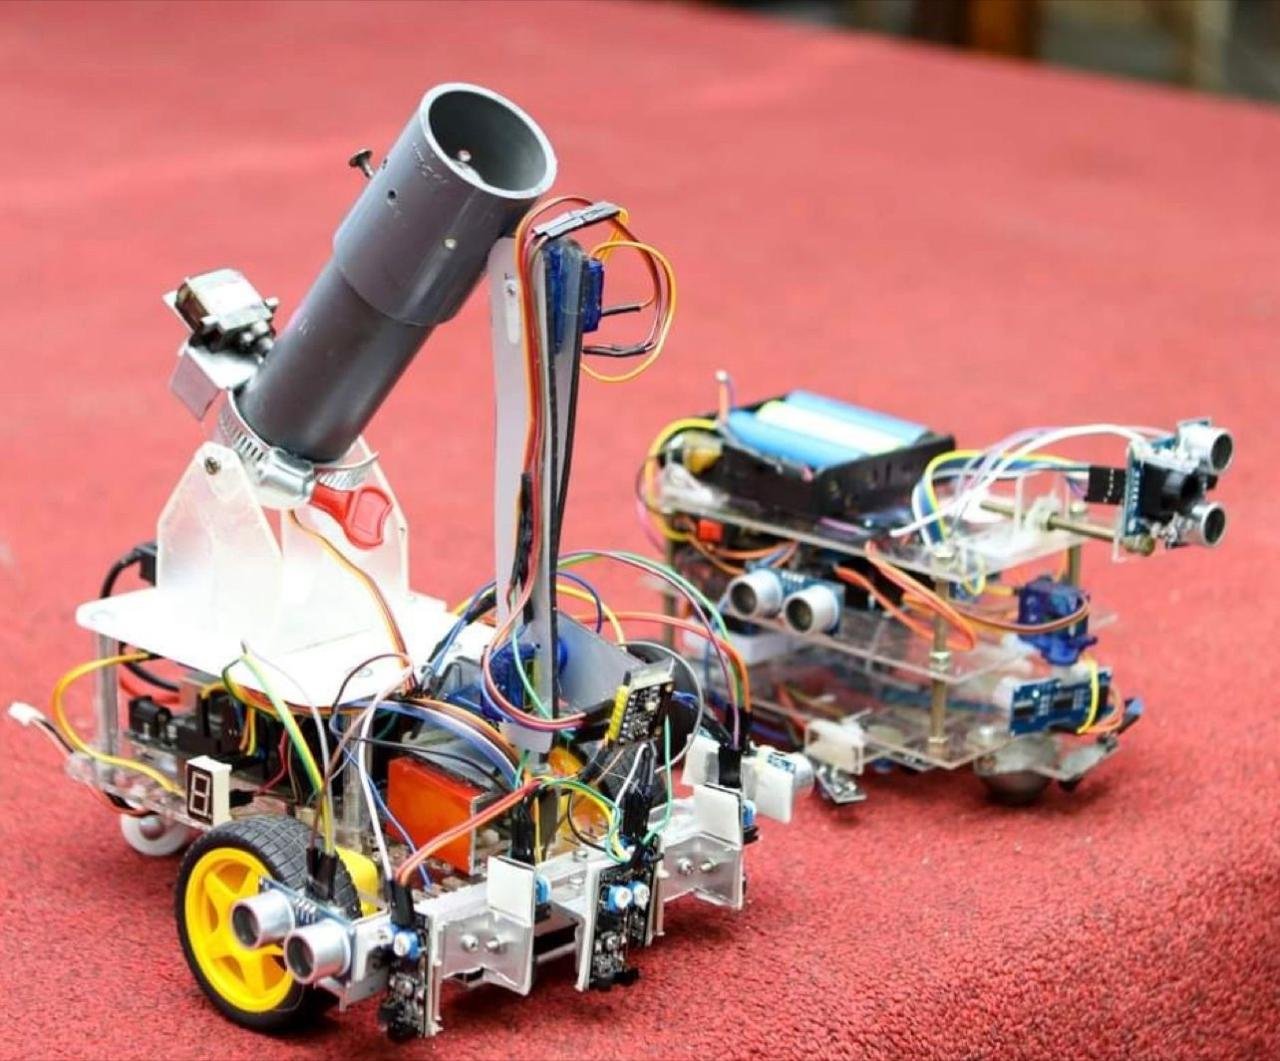
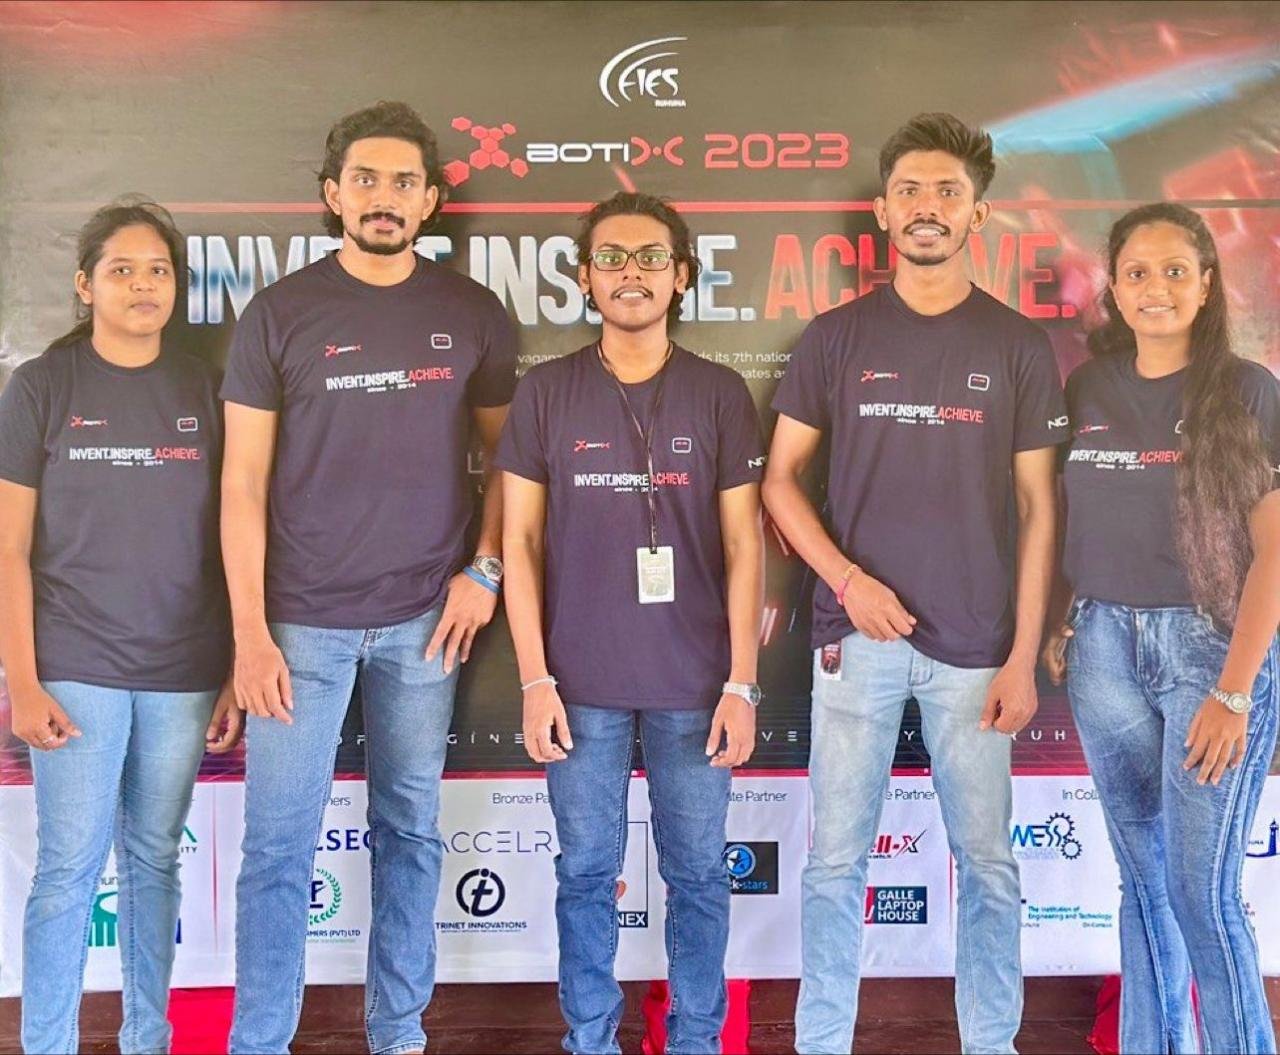
Team Sparkbots developed a task completion robot entry for XBOTIX 2023, the Ruhuna Robotics Challenge at the Faculty of Engineering, University of Ruhuna. The supplied photographs show the built hardware and the five-member team at the event.
The hardware photograph shows two wheeled platforms with layered chassis, exposed electronics and wiring, and ultrasonic sensor modules positioned around the vehicles. The taller platform carries a raised tubular mechanism and a vertical mechanism assembly; the smaller platform has compact mechanisms mounted between its chassis layers.
These photographs record the physical integration of mobility, sensing and task mechanisms. Controller models, sensor calibration, control code and the exact competition task sequence are not specified in the supplied resources.
I participated in Team Sparkbots alongside Janitha Karunarathna, Chamika Dilshan, Sasini Perera and Hansika Karunathilake. Together, we developed the competition entry and brought the assembled robot hardware to the challenge.
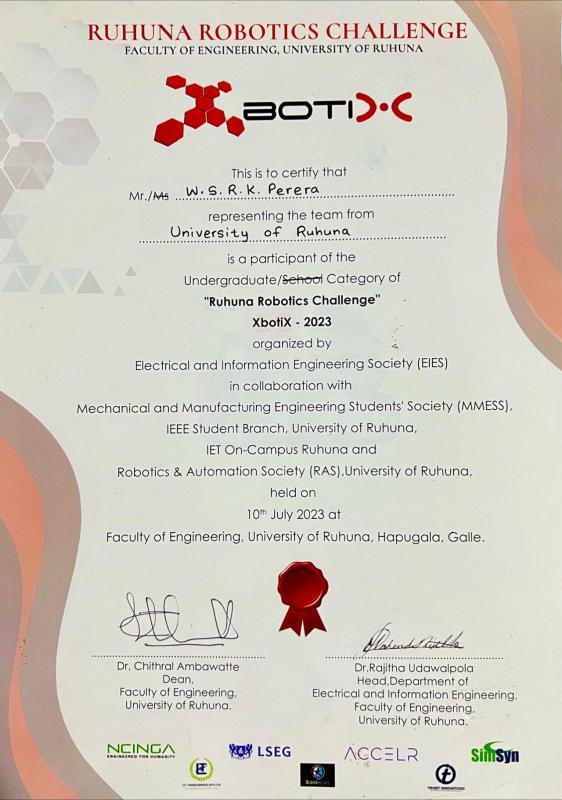
The supplied certificate names W. S. R. K. Perera, representing the University of Ruhuna, as an undergraduate participant in Xbotix 2023. It records the event on 10 July 2023 at the Faculty of Engineering in Hapugala, Galle.
The Electrical and Information Engineering Society organized the challenge in collaboration with MMESS, the university’s IEEE Student Branch, IET On-Campus Ruhuna and the Robotics & Automation Society. The certificate confirms participation; no final ranking or task score is included.
The event date is shown separately from the July–August project period previously listed in my portfolio.
The team also developed Sparkbot, the maze solving Micromouse for Robofest 2023. Its robot photographs, flood-fill implementation and final-round qualification are documented on that project’s own page.
An overview of the documented project scope.
Original robot and team photographs, plus the participation certificate, are available in the gallery above. The public project description supplies the project and collaborator context.
KEEP EXPLORING
01A fabricated and flight-tested electric UAV using three tilting propulsion units for vertical lift and transition to wing-borne forward flight.
 02
A station-supported free-flying robot design for orbital inspection, positioning, assembly, and servicing, with nitrogen propulsion and six modular docking interfaces.
 03
Designed in SolidWorks for Michelin and developed into a siever prototype, combining mechanical fabrication, electrical motor wiring, and hands-on troubleshooting.